

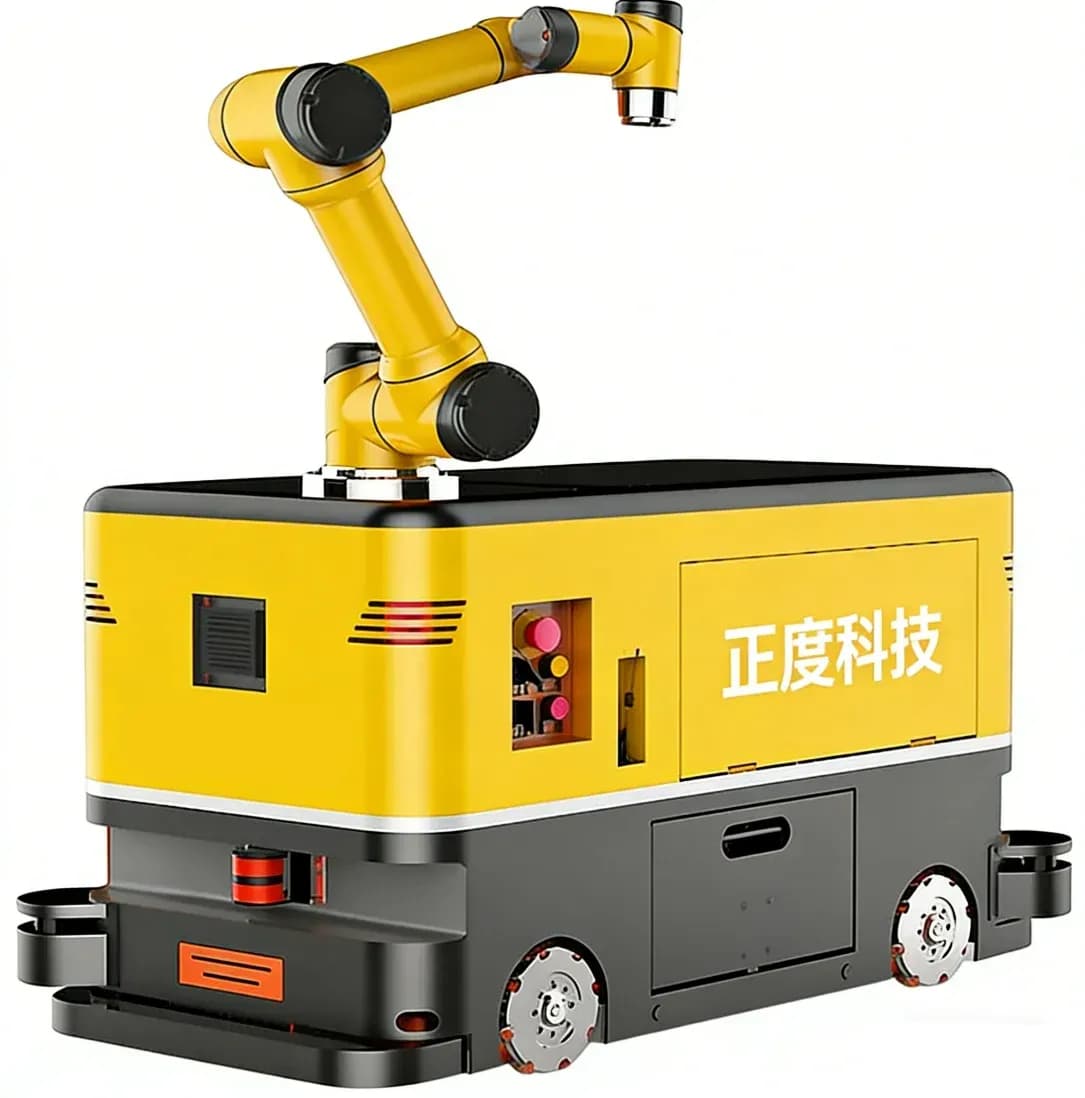
Mobile manipulators
Mobile manipulator AGV
Combines a mobile platform with a robotic arm for travel between workstations and on-site handling. Supports forward and reverse travel, turning and rotation in place.
Specifications
- Drive configuration
- Two-wheel differential drive
- Unloaded speed
- 1 m/s
- Positioning accuracy
- ±10 mm
- Navigation
- SLAM natural navigation